Explained
Combat Robot Radio Failsafes: Configure the Chain and Pass the TRBL Test
A step-by-step TRBL-focused check of receiver and ESC behavior, the transmitter-off test, and what the 1-second limit actually measures.
TRBL checks the complete control chain, from the transmitter and receiver to the ESCs controlling drive and weapon systems. Its English rules summary, revised 14 September 2026, says loss of signal, transmitter shutdown or a dropped link must cut power to drive and weapon systems within 1 second. The summary also says the Turkish rulebook is binding and applies if the English summary differs.
Configure the signal-loss response
Before inspection, set the receiver’s signal-loss response to neutral or no output, disable hold-last-command behavior, and verify by switching off the transmitter that power to both drive and weapon systems is cut within 1 second.
The receiver and ESC behavior both matter. TRBL’s radio and receiver guidance identifies hold-last-command as a dangerous configuration because the robot can continue executing its most recent command after the transmitter is switched off. Check that the receiver drops the throttle channels to neutral or stops producing an output, then confirm that each ESC responds by removing power rather than maintaining drive or weapon operation.
Reproduce the inspection test
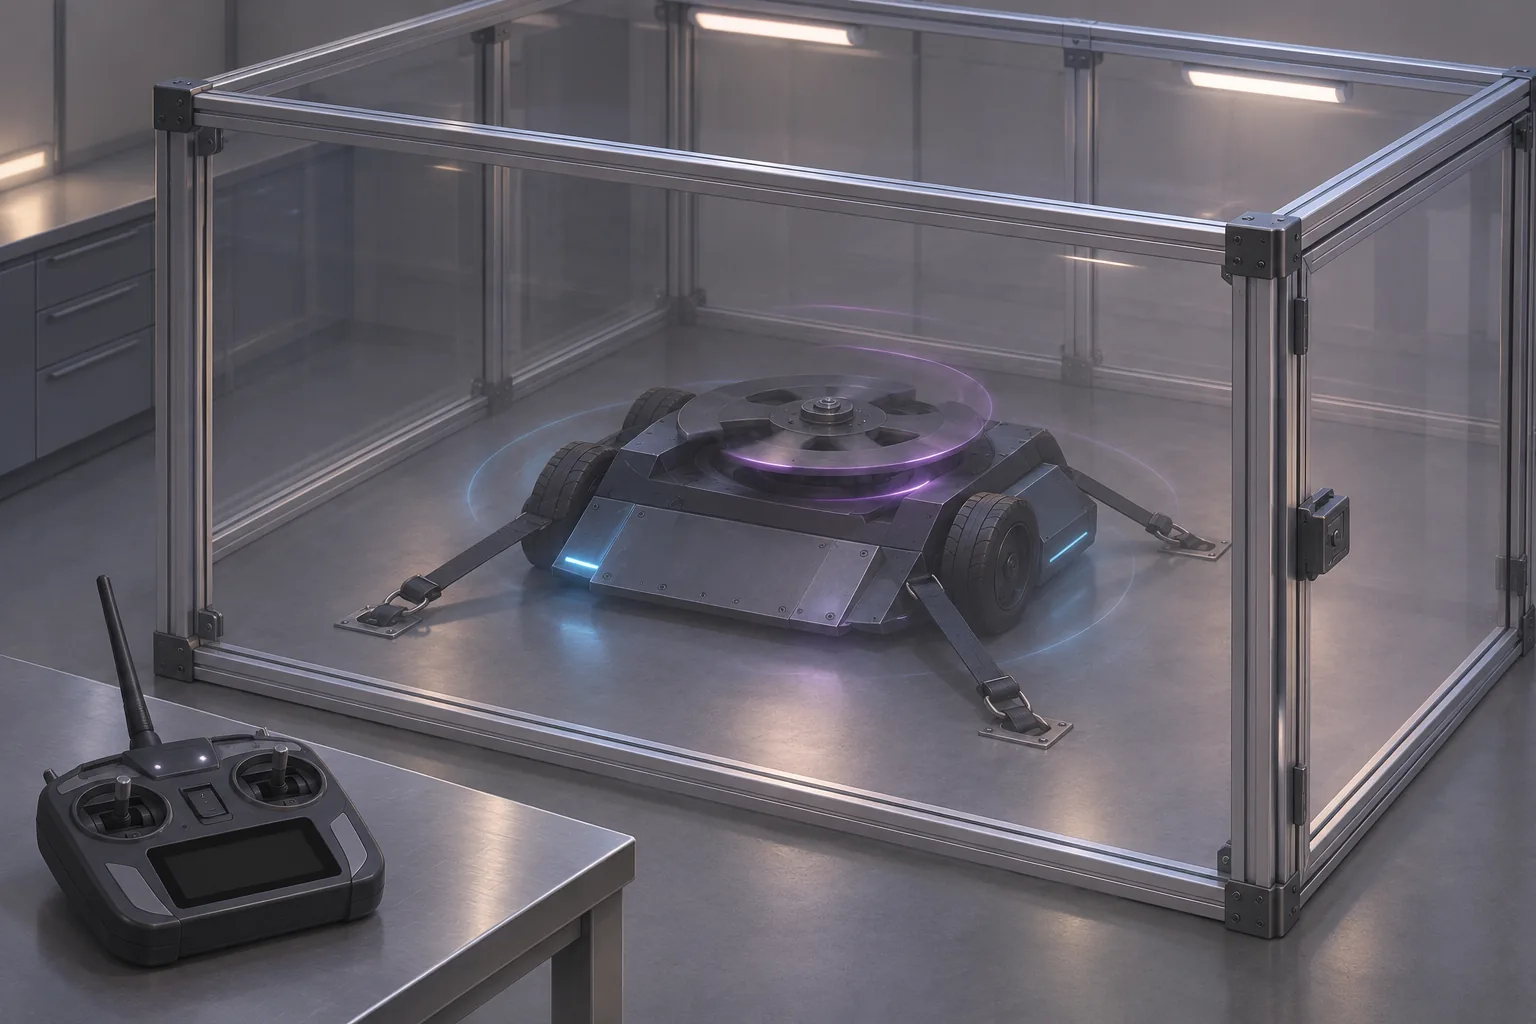
Test the configured robot in the workshop by switching off its transmitter, which is the method described for TRBL technical inspection. Measure the interval to the power cut, not the time required for a spinning weapon to coast to a complete stop. The guidance treats that spin-down period separately and says it is measured and declared during inspection.
The expected result is an observable loss of power to every drive and weapon system within 1 second. A robot that does not meet that requirement cannot fight under the summarized TRBL rules. For a multibot, each part needs its own receiver, so each receiver and its connected control chain must satisfy the same shutdown requirement.